15 skills · 5 robots
Skills your robot can learn.
Each skill is a short file: neural pathways, target poses and a test it must pass with stimulation and fail without. Pick one, or upload demonstrations and the platform writes one for you.
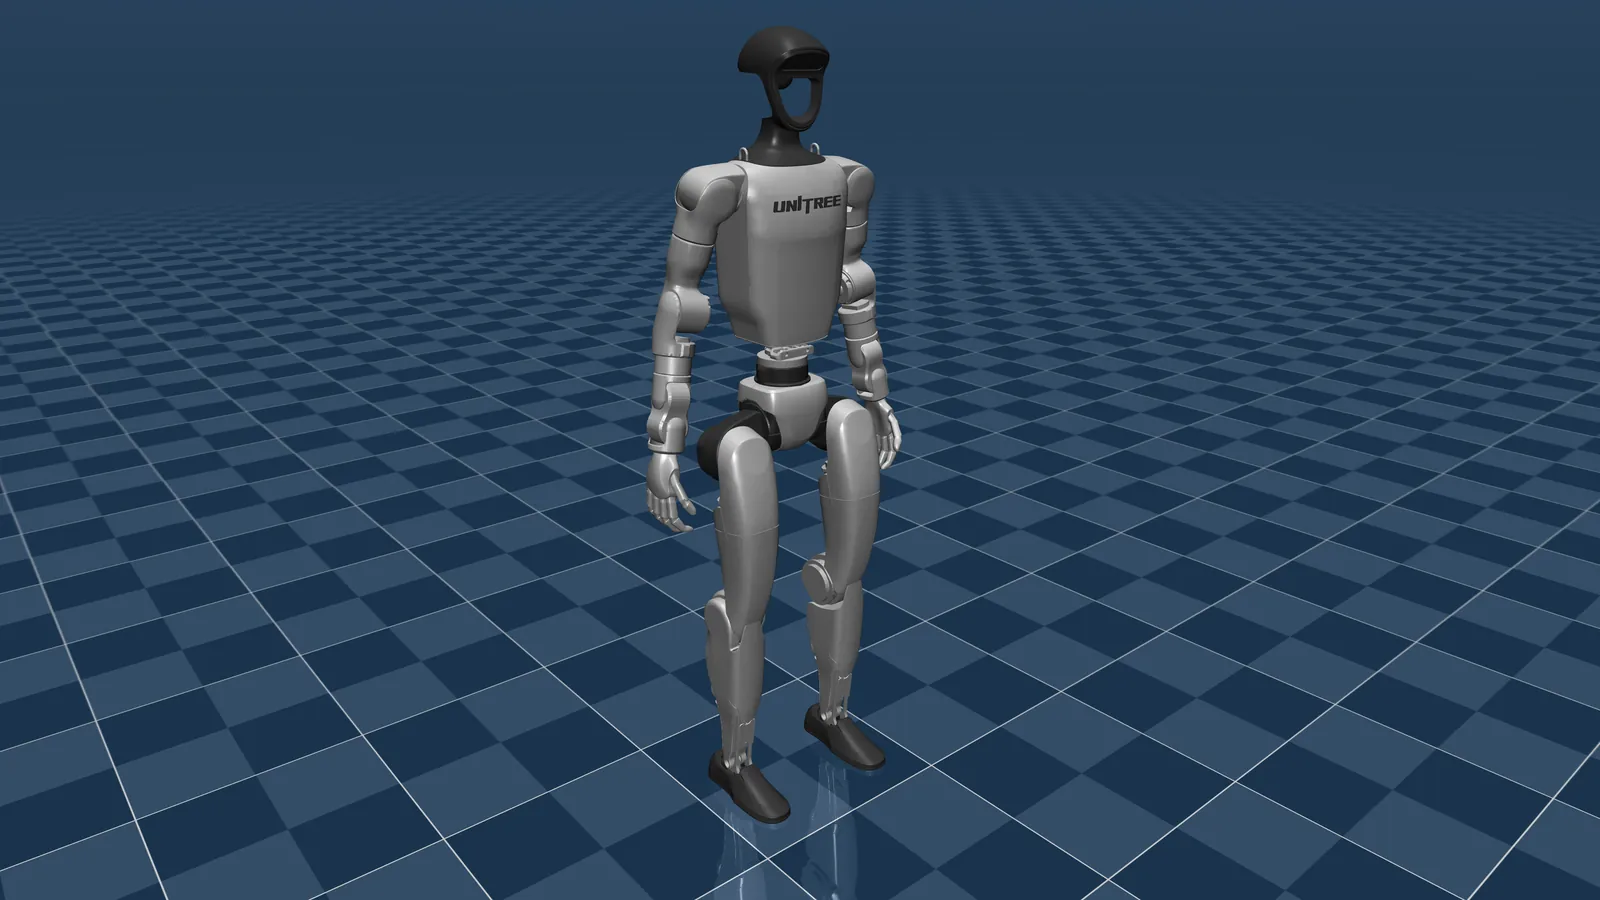
Humanoid · 4 skills
Unitree G1
- 01Raise right arm1 pathway · 6 s testRaise the right arm only while the “right arm” pathway of the neurons is ON.
- 02Two-arm choice2 pathways · 7 s testTwo pathways, two arms: whichever pathway the neurons answer on, that arm rises.
- 03Look toward activity (watch-only)Watch-onlyNo stimulation: the robot turns toward whichever half of the array is more active.
- 04Wave hello1 pathway · 6 s testThe right arm goes up and the forearm swings side to side only while “wave” is ON.
Robot arm · 2 skills
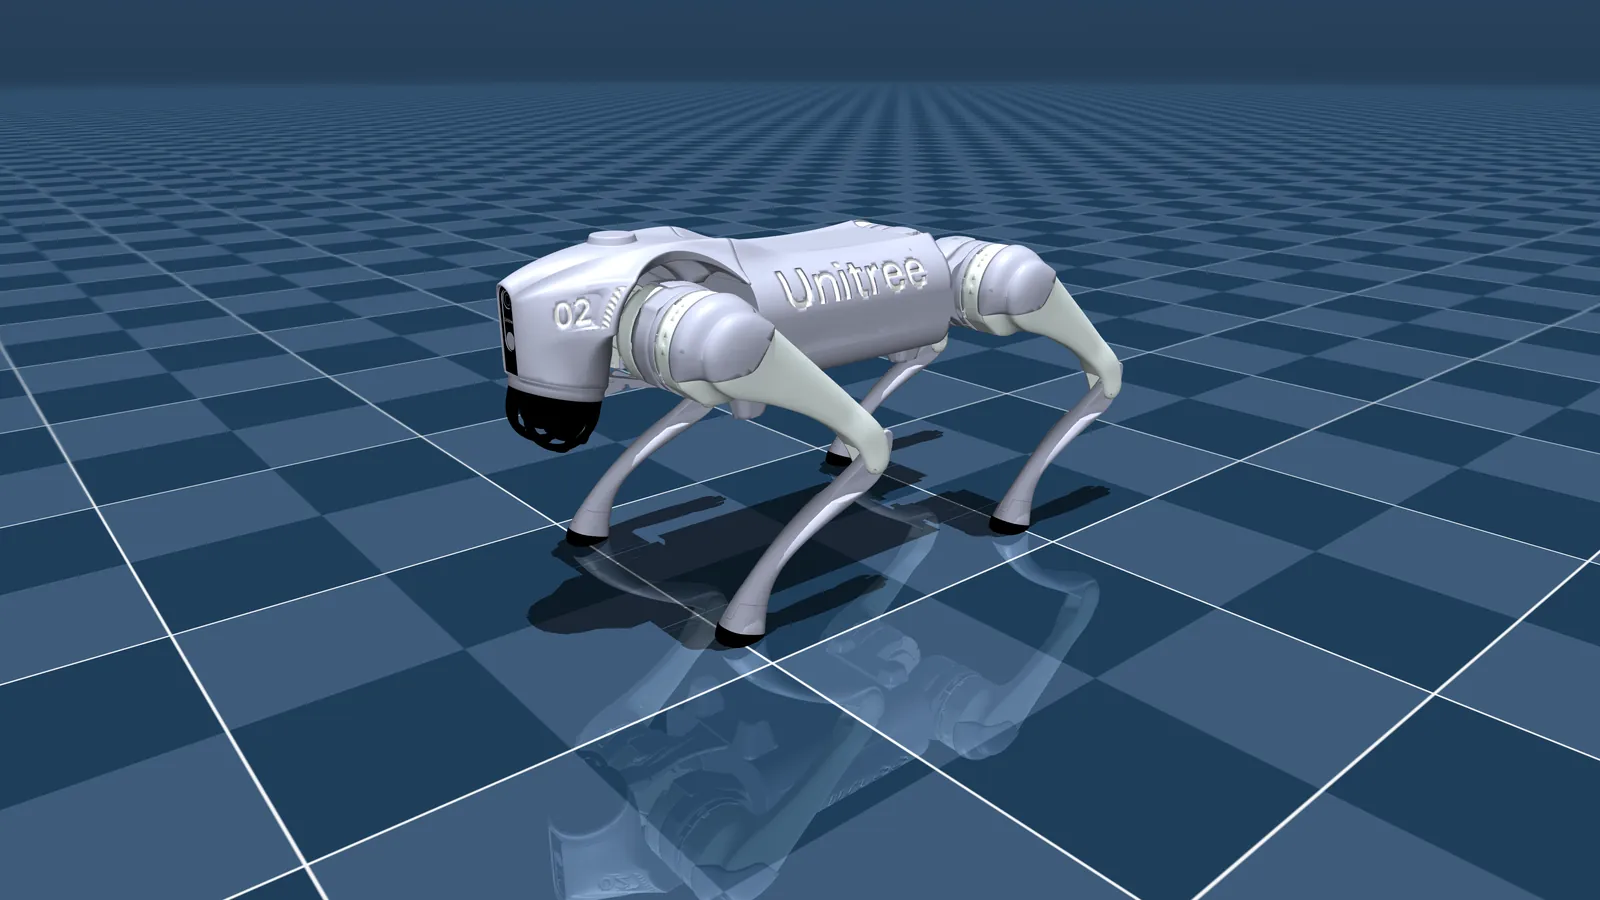
Quadruped · 4 skills
Unitree Go2
- 01Sit1 pathway · 6 s testThe quadruped stands at rest and sits down only while the “sit” pathway is ON.
- 02Give paw1 pathway · 6 s testShift weight onto three legs, then lift the front-right paw, only while “paw” is ON.
- 03Lean left / right2 pathways · 7 s testTwo pathways: the robot leans its body to the left or to the right, whichever pathway is ON.
- 04Walk forward1 pathway · 8 s testA trotting rhythm whose size follows the “walk” pathway, so the robot walks only while it is ON.
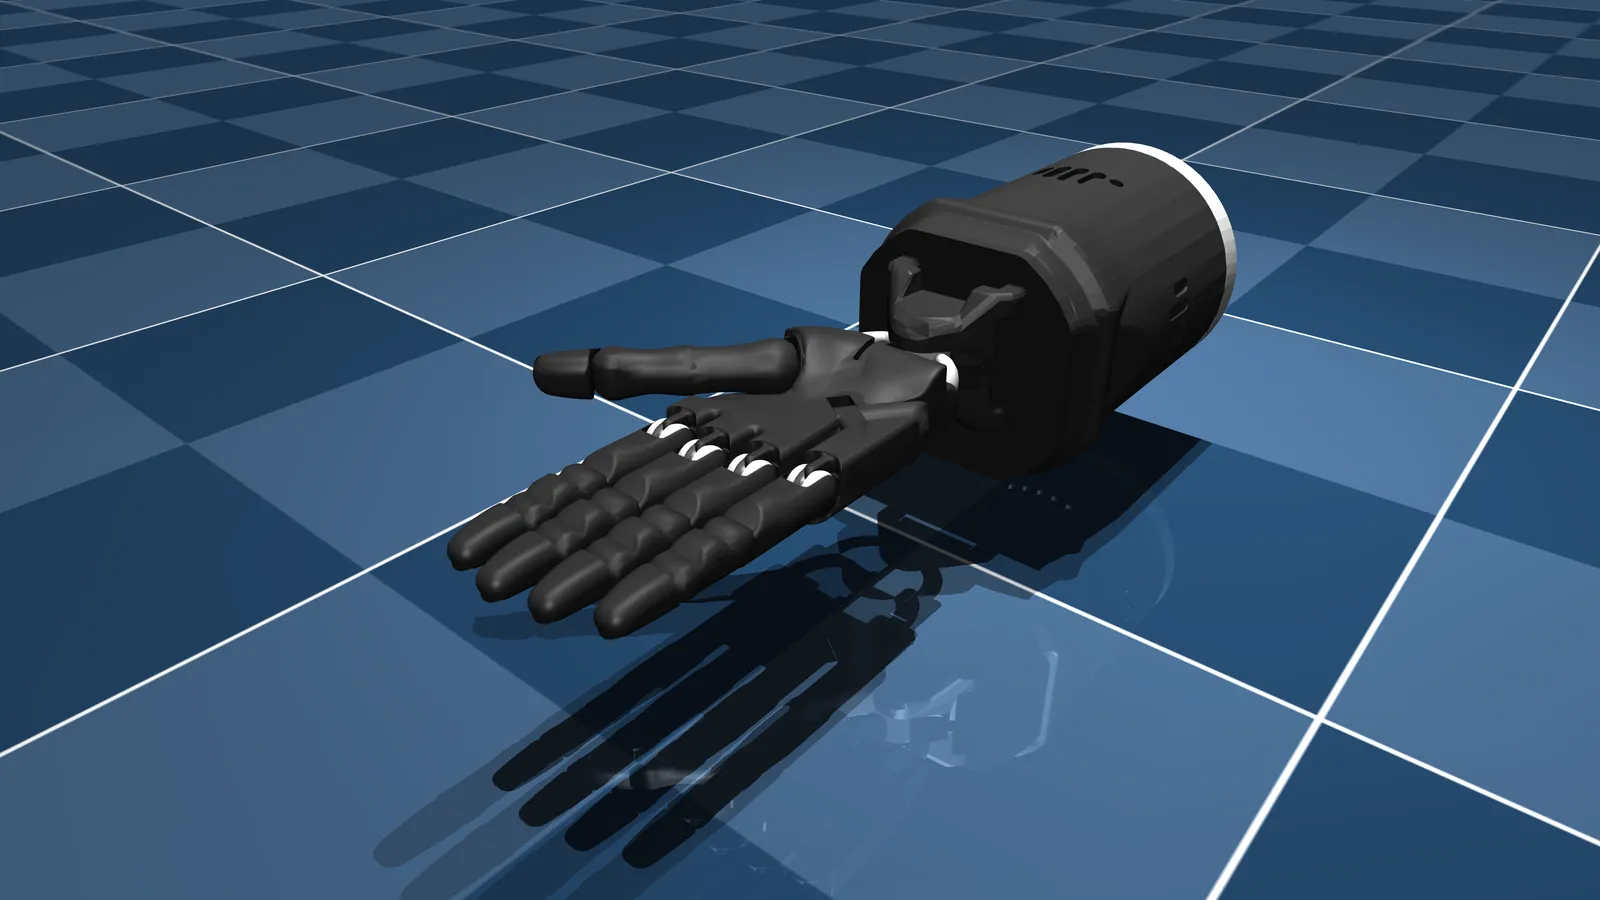
Dexterous hand · 3 skills
Shadow Hand
- 01Close fist1 pathway · 6 s testThe Shadow Hand closes into a fist only while the “fist” pathway is ON.
- 02Pinch1 pathway · 6 s testThumb and index fingertips meet in a pinch only while the “pinch” pathway is ON.
- 03Count fingers5 pathways · 11 s testFive pathways, one per finger. Each finger folds only while its own pathway is ON.
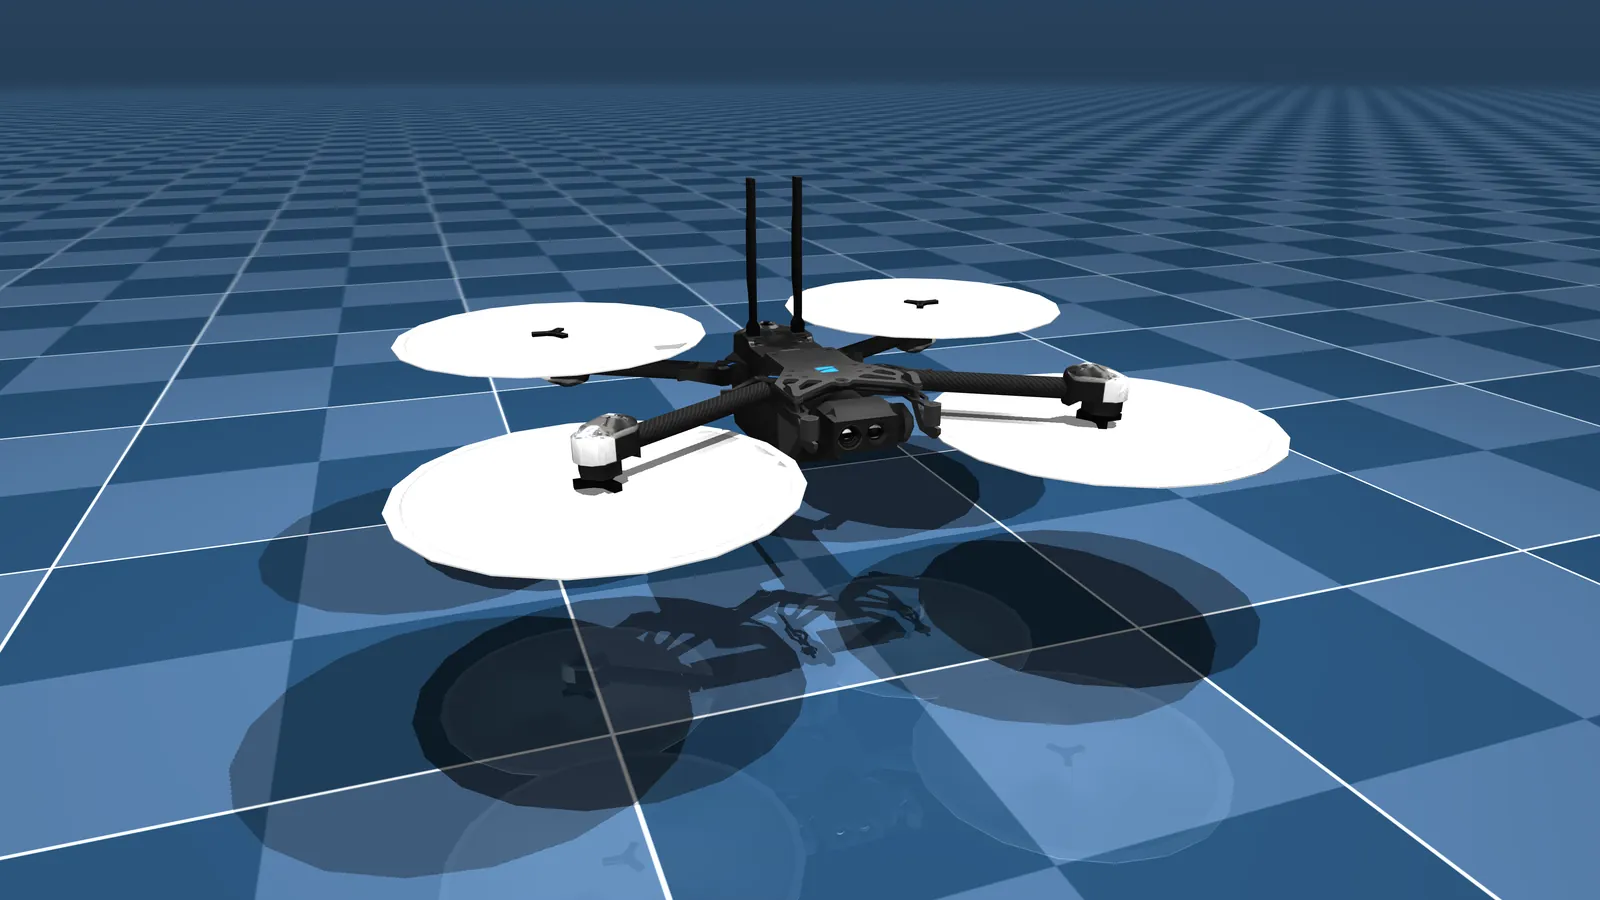
Drone · 2 skills
Your own skill
Or teach it from demonstrations.
Upload a CSV or JSON of joint positions recorded on your robot: a time column plus one column per joint, named like the robot’s controls. Every pose the robot holds still for at least 0.25 s becomes a target, the first one is rest, and each target gets its own pathway and a test that cues it.
Next step
Start with one skill.
Pick a robot and a skill, choose a biocomputer, and launch. In the sandbox a run takes about 1–2 min.