Robot arm · 2 skills
Franka Panda
A seven-joint arm with a parallel gripper. Skills set every joint and open or close the gripper.
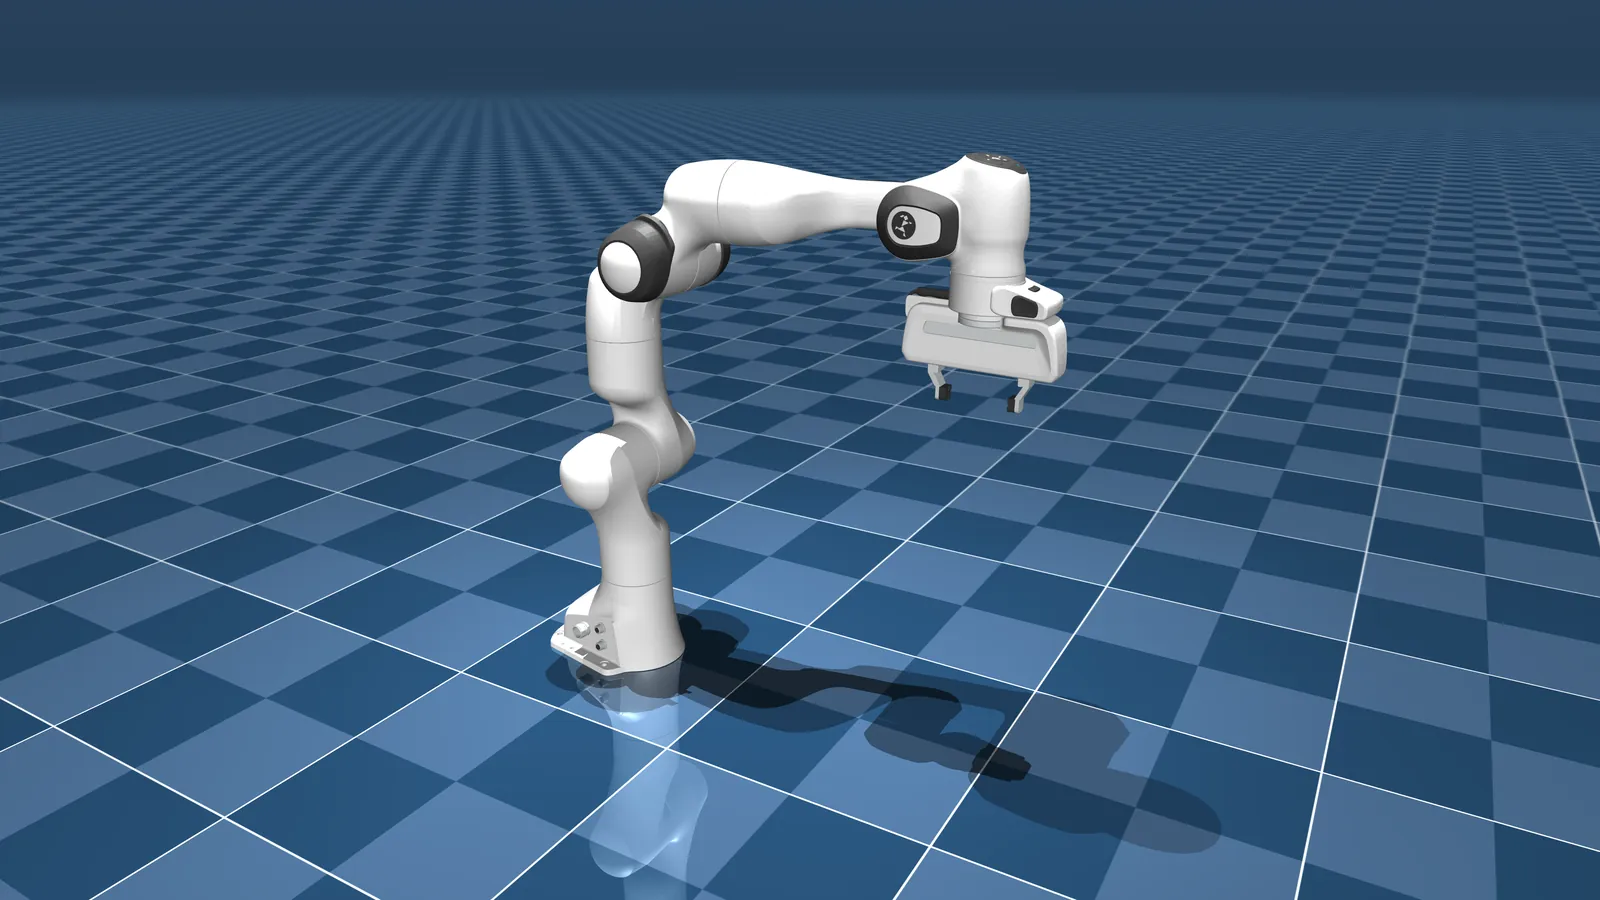
Franka Panda · MuJoCo Menagerie model · franka_emika_panda
01 Skills
What the Franka Panda can learn.
Each skill pairs neural pathways with target poses and a test the robot must pass with stimulation and fail without it.
02 Controls
What the neurons can move.
8 controls in all. A skill sets their targets; the simulator does the rest.
- Arm joints
- 1 · 2 · 3 · 4 · 5 · 6 · 7
- Gripper
- open or close (0 = closed, 255 = open)
03 Physics
Real physics, on our servers.
The Franka Panda is simulated with MuJoCo 3.12, the official WebAssembly build, on the server; your browser loads the same model only to draw it. The model comes unmodified from Google DeepMind’s MuJoCo Menagerie.
- Engine
- MuJoCo 3.12, WebAssembly, server-side
- In the simulator
- 7-joint arm with a parallel gripper (gripper: 0 = closed, 255 = open).
Franka Panda
Teach the Franka Panda its first skill.
Pick a skill or upload demonstrations, choose a biocomputer, and get a policy that passed both negative controls.