Humanoid · 4 skills
Unitree G1
A humanoid with its waist and both arms open to training, 17 joints in all. The floating base is held in place, because the simulator runs no balance controller.
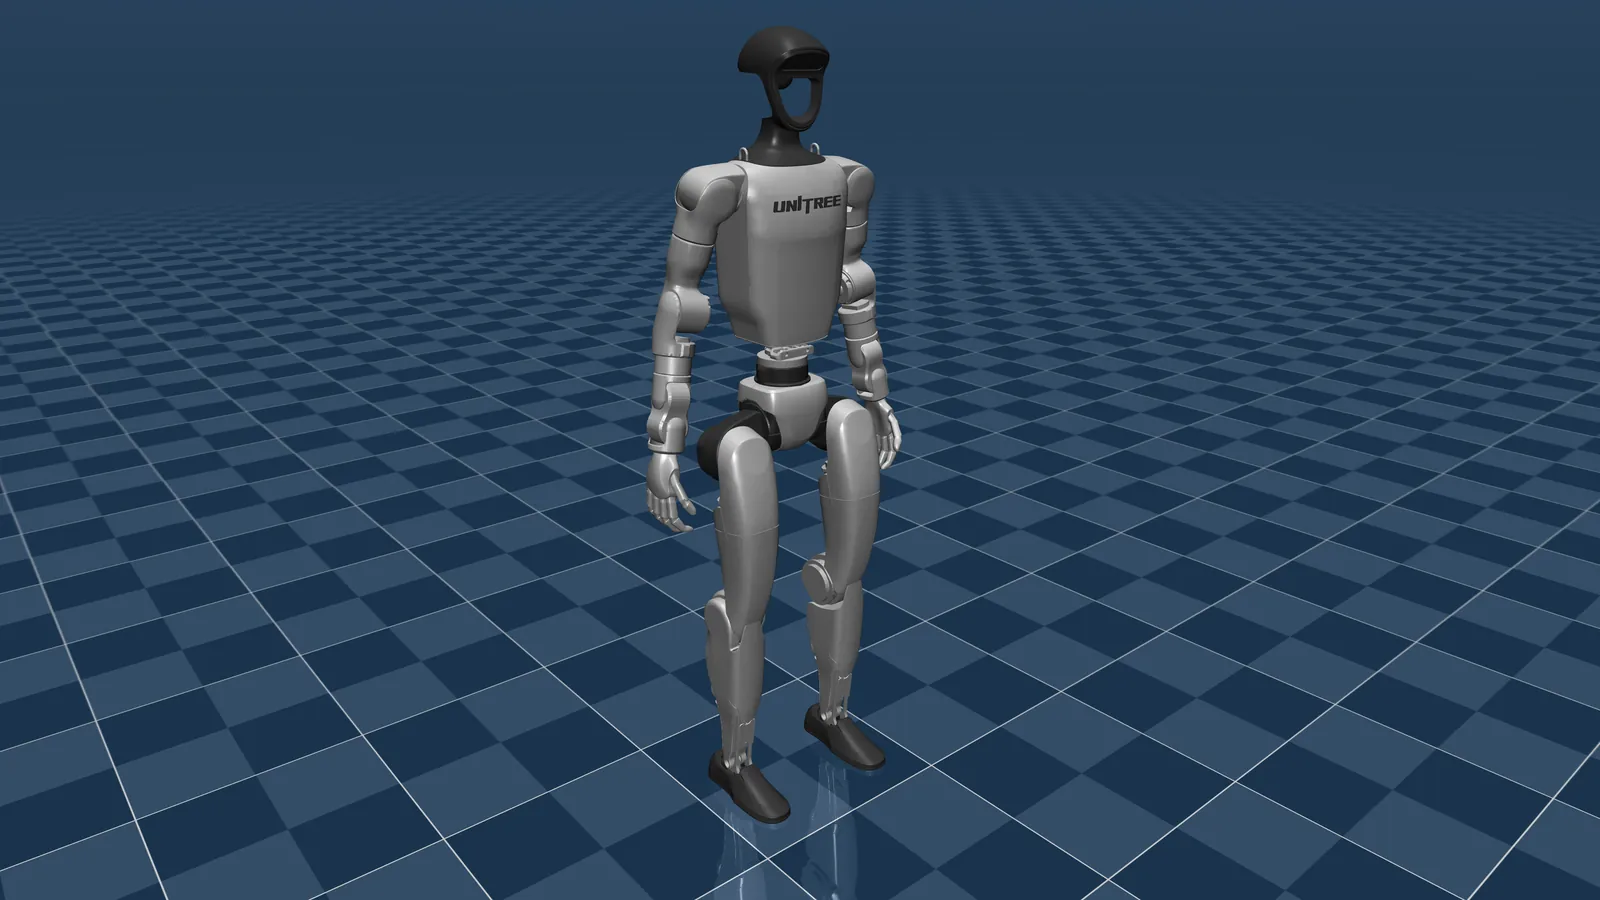
Unitree G1 · MuJoCo Menagerie model · unitree_g1
01 Skills
What the Unitree G1 can learn.
Each skill pairs neural pathways with target poses and a test the robot must pass with stimulation and fail without it.
- 01Raise right arm1 pathway · 6 s testRaise the right arm only while the “right arm” pathway of the neurons is ON.
- 02Two-arm choice2 pathways · 7 s testTwo pathways, two arms: whichever pathway the neurons answer on, that arm rises.
- 03Look toward activity (watch-only)Watch-onlyNo stimulation: the robot turns toward whichever half of the array is more active.
- 04Wave hello1 pathway · 6 s testThe right arm goes up and the forearm swings side to side only while “wave” is ON.
02 Controls
What the neurons can move.
17 controls in all. A skill sets their targets; the simulator does the rest.
- Waist
- yaw · roll · pitch
- Left arm
- shoulder pitch · shoulder roll · shoulder yaw · elbow · wrist roll · wrist pitch · wrist yaw
- Right arm
- shoulder pitch · shoulder roll · shoulder yaw · elbow · wrist roll · wrist pitch · wrist yaw
03 Physics
Real physics, on our servers.
The Unitree G1 is simulated with MuJoCo 3.12, the official WebAssembly build, on the server; your browser loads the same model only to draw it. The model comes unmodified from Google DeepMind’s MuJoCo Menagerie.
- Engine
- MuJoCo 3.12, WebAssembly, server-side
- In the simulator
- Humanoid, floating base held in place (no balance controller); waist and both arms are controllable.
Unitree G1
Teach the Unitree G1 its first skill.
Pick a skill or upload demonstrations, choose a biocomputer, and get a policy that passed both negative controls.