Dexterous hand · 3 skills
Shadow Hand
A right Shadow Dexterous Hand on a fixed forearm, palm up, with 20 position actuators. Each finger’s curl drives its two outer joints together through a tendon.
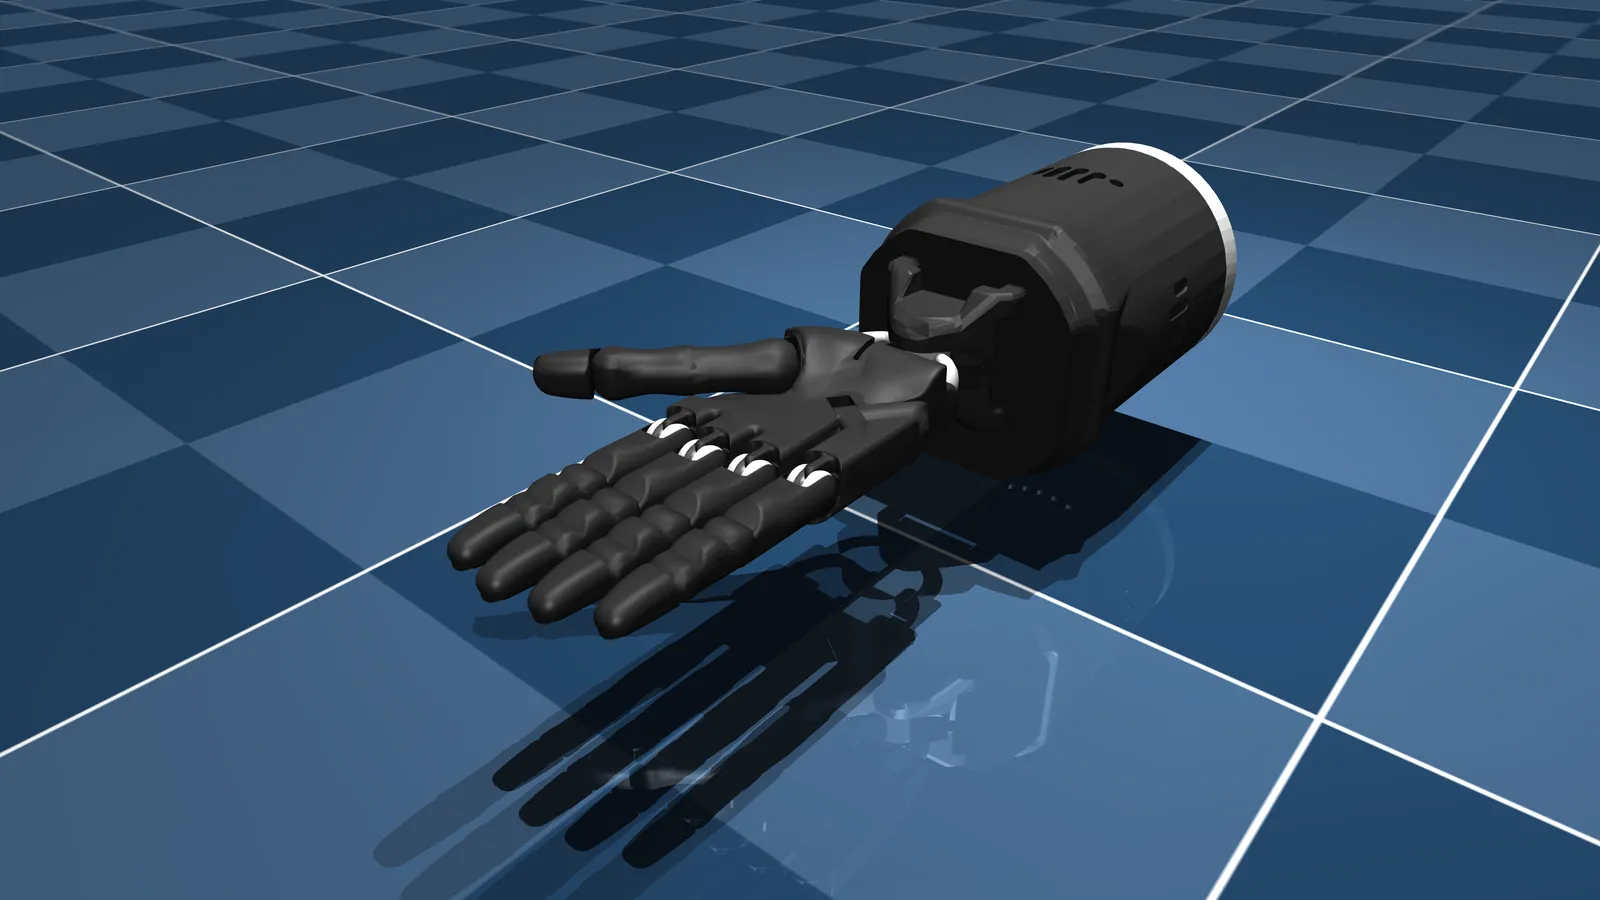
Shadow Hand · MuJoCo Menagerie model · shadow_hand
01 Skills
What the Shadow Hand can learn.
Each skill pairs neural pathways with target poses and a test the robot must pass with stimulation and fail without it.
- 01Close fist1 pathway · 6 s testThe Shadow Hand closes into a fist only while the “fist” pathway is ON.
- 02Pinch1 pathway · 6 s testThumb and index fingertips meet in a pinch only while the “pinch” pathway is ON.
- 03Count fingers5 pathways · 11 s testFive pathways, one per finger. Each finger folds only while its own pathway is ON.
02 Controls
What the neurons can move.
20 controls in all. A skill sets their targets; the simulator does the rest.
- Wrist
- tilt · flex
- Thumb
- rotate · flex · hub · bend · tip
- Index finger
- spread · flex · curl
- Middle finger
- spread · flex · curl
- Ring finger
- spread · flex · curl
- Little finger
- cup · spread · flex · curl
03 Physics
Real physics, on our servers.
The Shadow Hand is simulated with MuJoCo 3.12, the official WebAssembly build, on the server; your browser loads the same model only to draw it. The model comes unmodified from Google DeepMind’s MuJoCo Menagerie.
- Engine
- MuJoCo 3.12, WebAssembly, server-side
- In the simulator
- Right Shadow Dexterous Hand on a fixed forearm, palm up. 20 position actuators; each finger’s “curl” drives its two outer joints together through a tendon (0 to 3.14 rad).
Shadow Hand
Teach the Shadow Hand its first skill.
Pick a skill or upload demonstrations, choose a biocomputer, and get a policy that passed both negative controls.