Quadruped · 4 skills
Unitree Go2
A free-standing quadruped. Its 12 torque motors follow joint-angle targets through a PD loop, so a skill describes poses and rhythms, not torques.
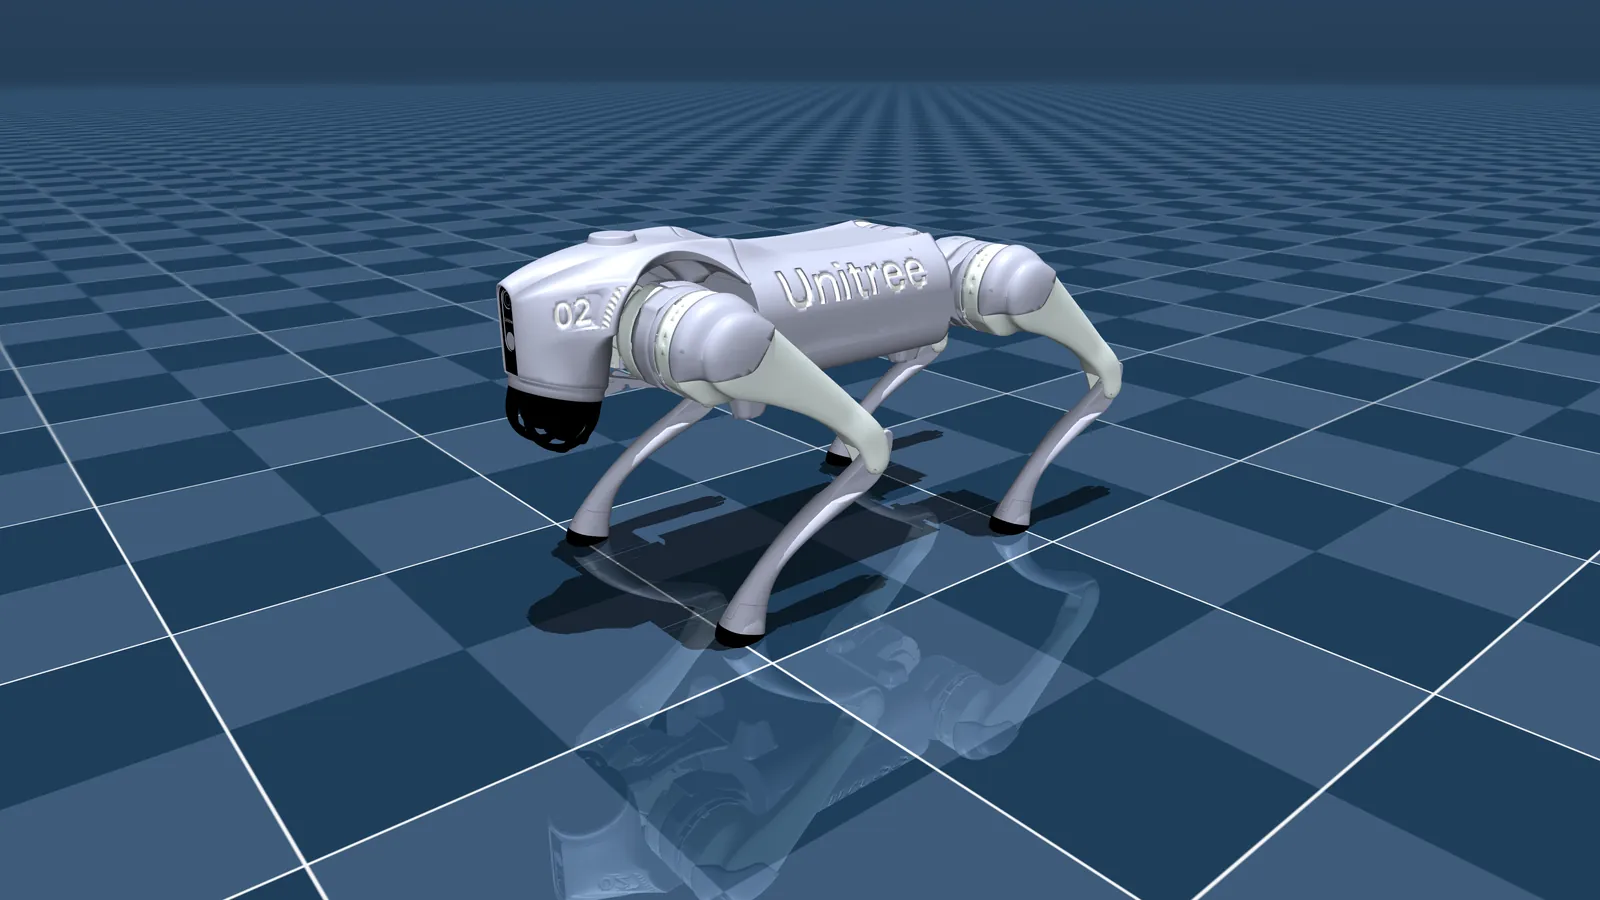
Unitree Go2 · MuJoCo Menagerie model · unitree_go2
01 Skills
What the Unitree Go2 can learn.
Each skill pairs neural pathways with target poses and a test the robot must pass with stimulation and fail without it.
- 01Sit1 pathway · 6 s testThe quadruped stands at rest and sits down only while the “sit” pathway is ON.
- 02Give paw1 pathway · 6 s testShift weight onto three legs, then lift the front-right paw, only while “paw” is ON.
- 03Lean left / right2 pathways · 7 s testTwo pathways: the robot leans its body to the left or to the right, whichever pathway is ON.
- 04Walk forward1 pathway · 8 s testA trotting rhythm whose size follows the “walk” pathway, so the robot walks only while it is ON.
02 Controls
What the neurons can move.
12 controls in all. A skill sets their targets; the simulator does the rest.
- Front-left leg
- hip · thigh · calf
- Front-right leg
- hip · thigh · calf
- Rear-left leg
- hip · thigh · calf
- Rear-right leg
- hip · thigh · calf
03 Physics
Real physics, on our servers.
The Unitree Go2 is simulated with MuJoCo 3.12, the official WebAssembly build, on the server; your browser loads the same model only to draw it. The model comes unmodified from Google DeepMind’s MuJoCo Menagerie.
- Engine
- MuJoCo 3.12, WebAssembly, server-side
- In the simulator
- Free-standing quadruped. Its 12 torque motors are driven by a joint PD loop (targets are joint angles in rad).
Unitree Go2
Teach the Unitree Go2 its first skill.
Pick a skill or upload demonstrations, choose a biocomputer, and get a policy that passed both negative controls.