5 robots · real physics
Robots you can train with neurons.
Each robot runs in real MuJoCo physics on our servers, so you see exactly what the neurons make it do. Every one comes with skills ready to train, or you can teach it from your own demonstrations.
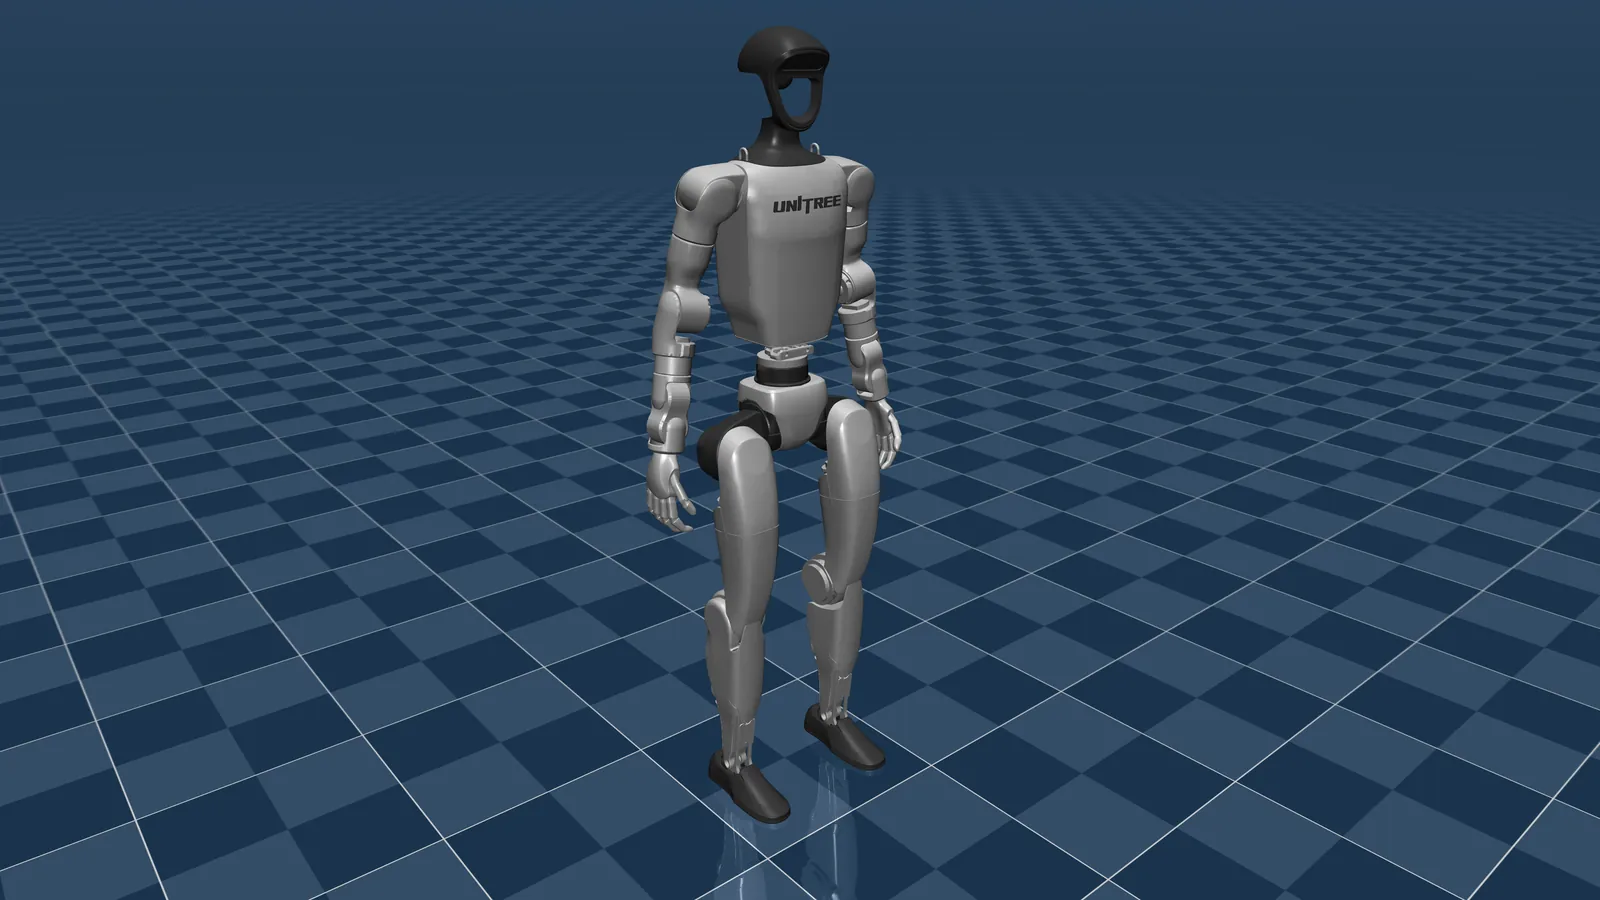
Unitree G1
A humanoid with its waist and both arms open to training, 17 joints in all. The floating base is held in place, because the simulator runs no balance controller.
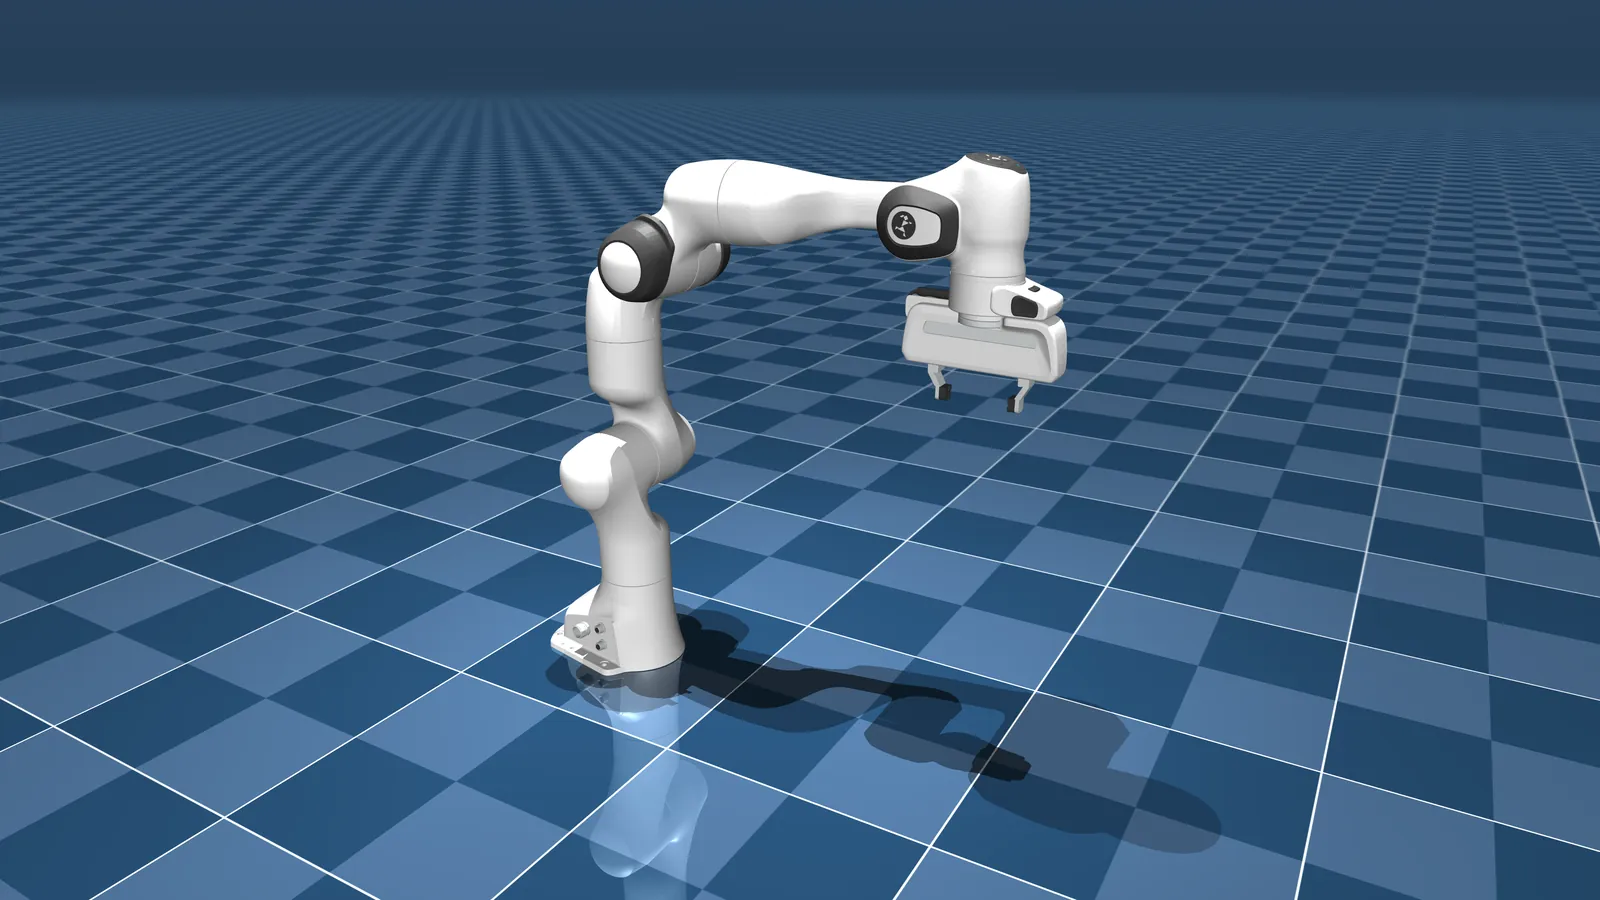
Franka Panda
A seven-joint arm with a parallel gripper. Skills set every joint and open or close the gripper.
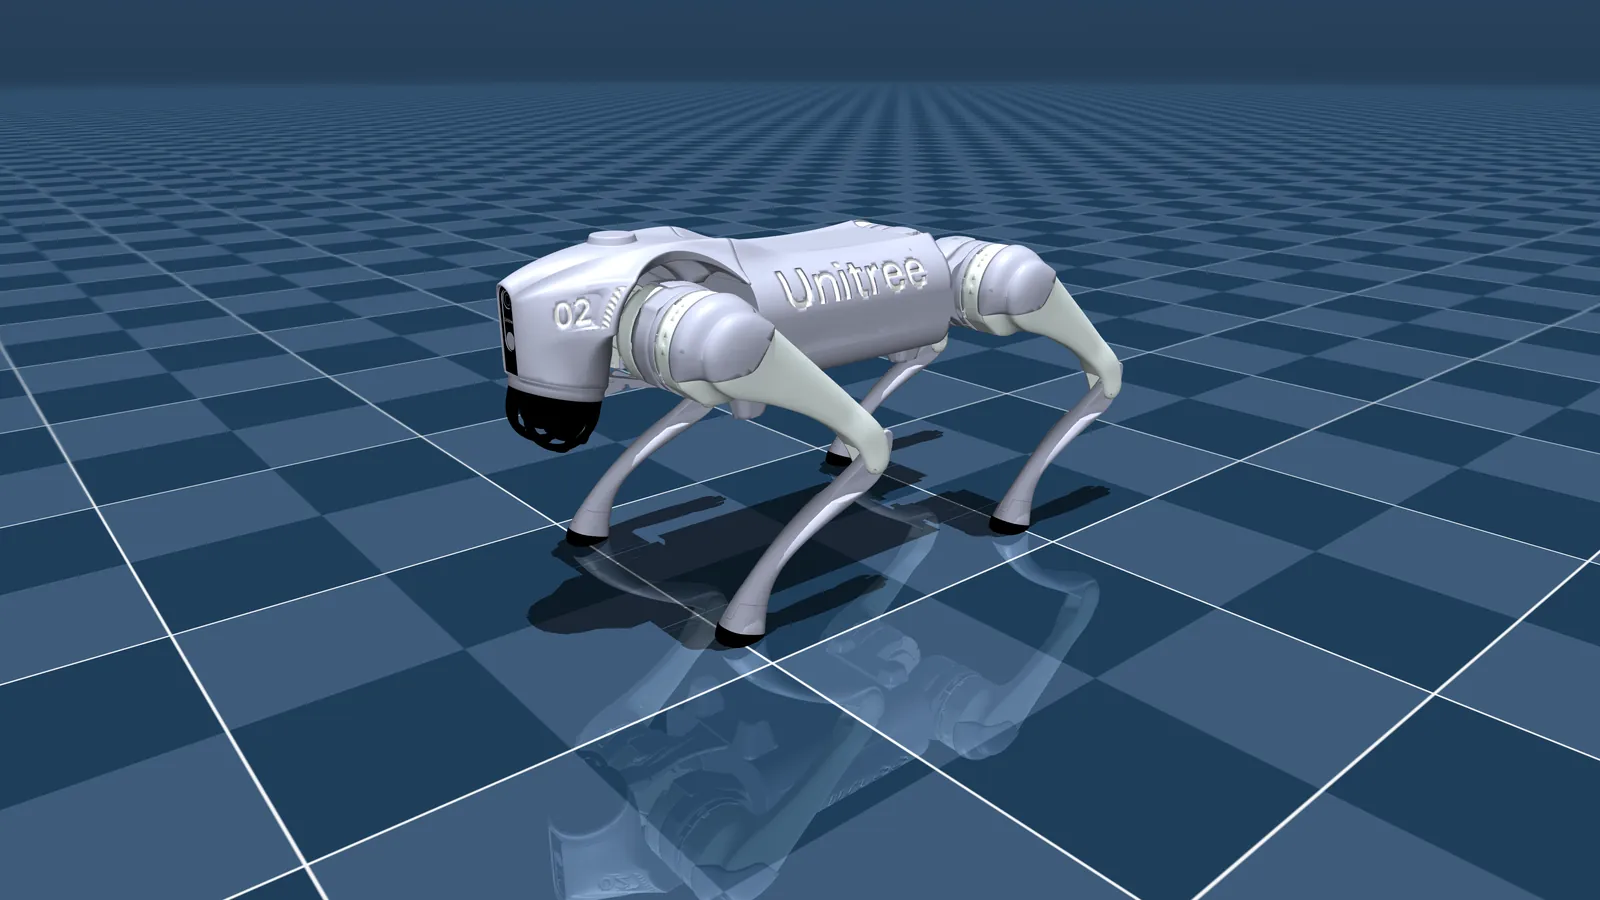
Unitree Go2
A free-standing quadruped. Its 12 torque motors follow joint-angle targets through a PD loop, so a skill describes poses and rhythms, not torques.
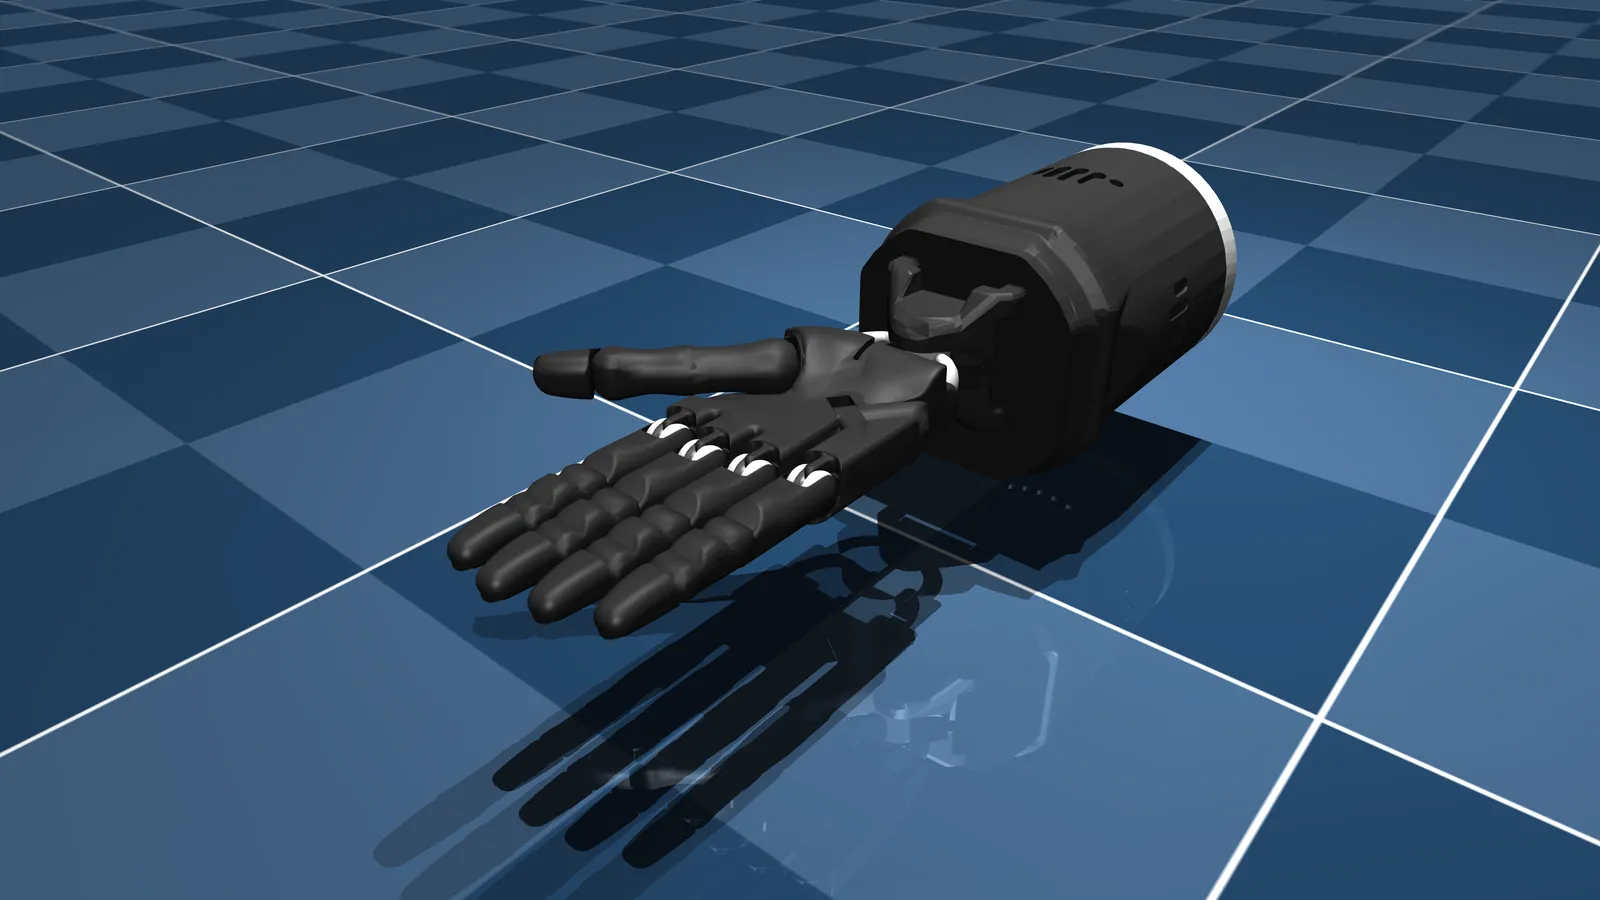
Shadow Hand
A right Shadow Dexterous Hand on a fixed forearm, palm up, with 20 position actuators. Each finger’s curl drives its two outer joints together through a tendon.
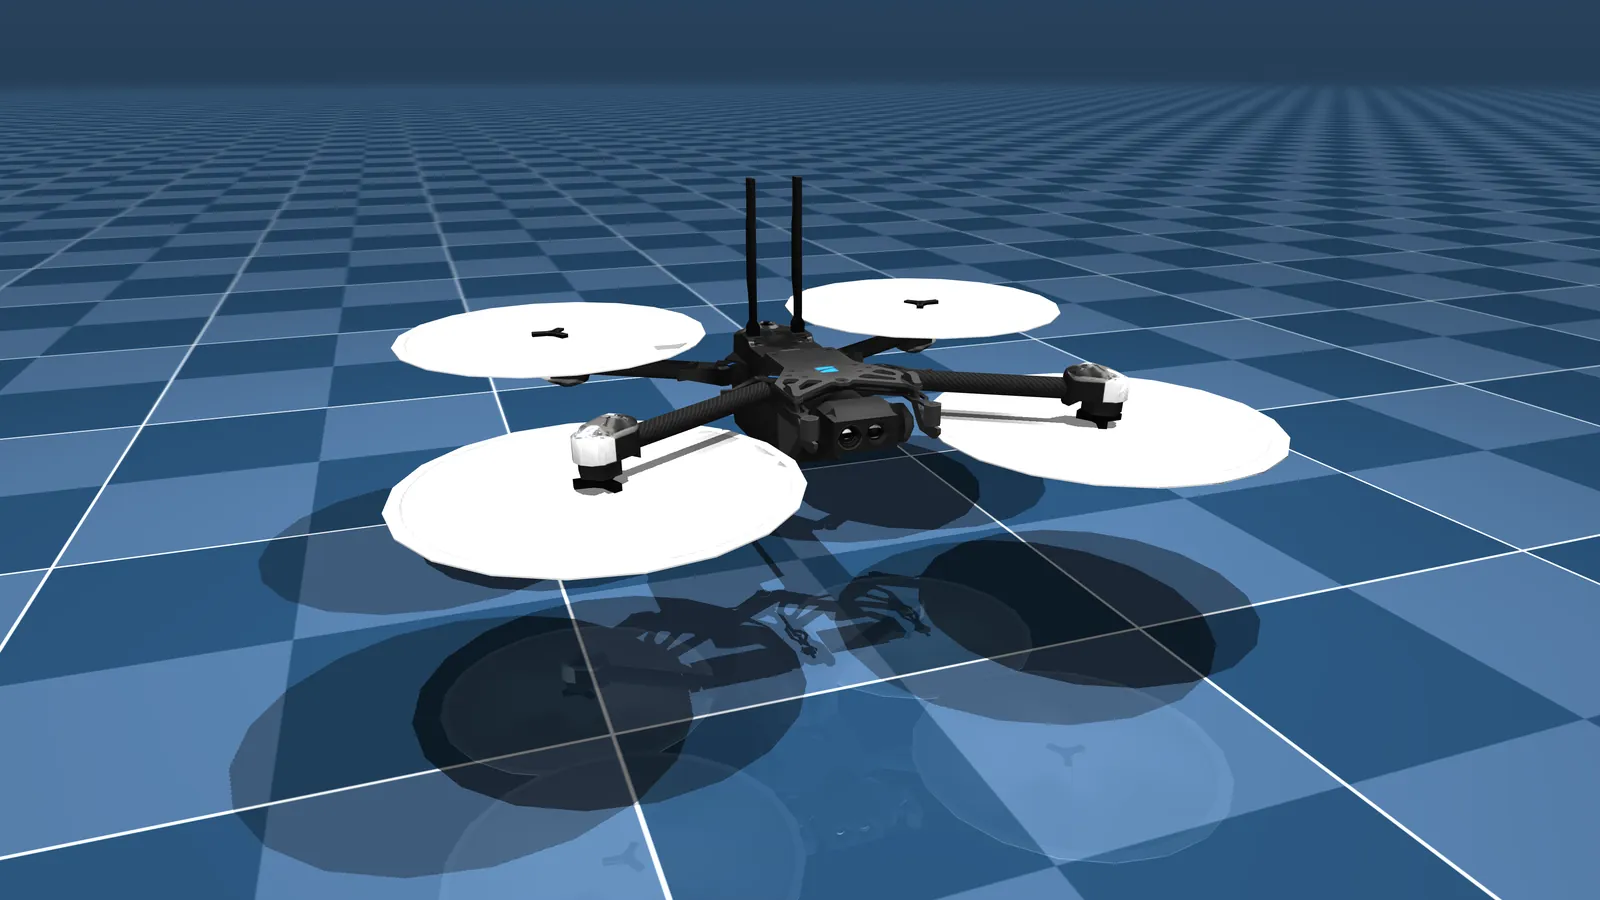
Skydio X2
A quadrotor flown by an onboard flight controller. Skills set where it should be: altitude, forward and lateral position, and yaw.
Next step
Pick a robot. Teach it a skill.
Choose a skill or upload demonstrations, then watch the neurons calibrate, train and validate it.